Self-serve · $19 once
Stress-test pack
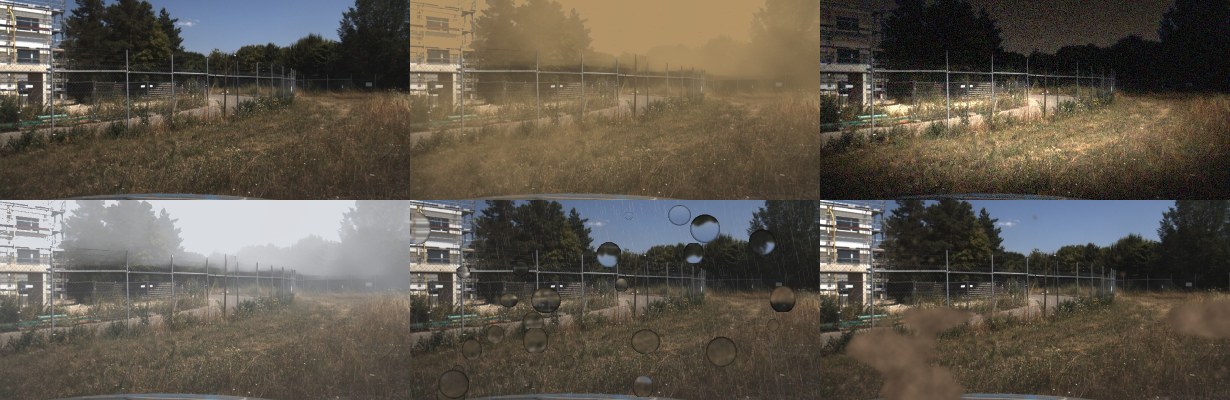
2,400 labelled off-road frames in dust, night, fog, rain and mud (3 severities each), plus real rain. Run your model on them, run our script, and see where it breaks — in about 10 minutes.
See the pack →Stress-test pack · GOOSE edition · v1
150 real off-road frames, each in dust, night, fog, rain on the lens and mud on the lens at three severities, plus 60 real rain and snow frames. All labelled. Run your model, run one script, get your failure map.
evaluate.py.python evaluate.py --pred your_predictions prints mIoU per condition and severity, the drop against clear weather, traversable-ground IoU and the classes that fail first.Different class set? Map yours to the 19 classes first, or leave out the ones you don’t have. Pixels a dense dust or fog veil makes physically invisible are marked void and never scored — no penalty for not seeing the invisible.
Secure checkout by Lemon Squeezy (card, Apple Pay, Google Pay, PayPal). Download link right after payment.
Free sample · 10 frames
Same structure, same evaluate.py, 10 frames in every condition.
Download siltframe-sample-stress-test.zip ↓Our own reference models on the pack. Yours comes out in the same format.
| Reference model | Clean mIoU | Dust | Night | Fog | Rain on lens | Mud on lens | Real rain / snow |
|---|---|---|---|---|---|---|---|
| SegFormer-B0, RELLIS-3D + GOOSE train | 52.5 | −43% | −61% | −20% | −41% | −20% | −12% |
| Mask2Former Swin-T, RELLIS-3D + GOOSE train | 58.1 | −35% | −56% | −16% | −41% | −19% | −8% |
| SegFormer-B0, RELLIS-3D only | 14.5 | −43% | −69% | −23% | −23% | −10% | −3% |
Self-serve · $19 once
2,400 labelled off-road frames in dust, night, fog, rain and mud (3 severities each), plus real rain. Run your model on them, run our script, and see where it breaks — in about 10 minutes.
See the pack →Done for you · from $300
We test your model on your frames, find why it fails — like tree canopy read as sky in our own case study — and hand you a report with a ranked fix list: which real data to capture, what to synthesise.
Sample report →Done for you · from $300
Your own labelled frames rendered in the conditions you can’t easily capture — dust, night, rain, mud, fog — with labels kept pixel-exact.
Send a brief →